Perception
Overview
Section titled “Overview”For the perception starter project, you will implement a ROS2 node that uses camera data to detect ArUco tags using OpenCV, a popular computer vision library. Navigation will read this data in order to drive towards and align the rover with it.
Example ArUco tags are pictured below. ArUco tags have an ID that corresponds to the pattern it contains.

The ROS2 jazzy wiki, software leads, and fellow members are a great resource if you are struggling with anything. Don’t be afraid to ask questions; it’s how we learn!
Nodes, Topics, Publishers, and Subscribers
Section titled “Nodes, Topics, Publishers, and Subscribers”Before we start, let’s clarify some unique ROS features and vocabulary. What are nodes and topics? What does “publish” or “subscribe” mean? First, let’s talk about nodes. You may have written programming projects in the past that start in a main() function, and then run sequentially before exiting. In contrast, you can think of ROS2 projects as being a collection of independent processes constantly running at the same time. Each of the processes is called a “node”, and they usually do not exit unless the user stops it.
It usually isn’t very useful to have a bunch of nodes that are unable to communicate with each other. This is where publishers, subscribers, and topics come in. Nodes can instantiate publishers, which send, or “publish”, data to a named topic. Other nodes then might instantiate subscribers, which retrieve, or “subscribe”, data from a named topic. The data being sent back and forth are called messages. Publishers and subscribers do not know about who is sending or retrieving the information, just the name of the topic it is reading from. Multiple publishers can publish to the same topic, and multiple subscribers can subscribe to the same topic. Additionally, nodes may have any amount of publishers/subscribers.
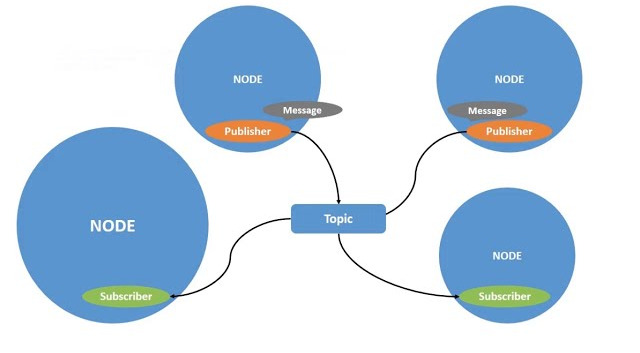
A helpful analogy might be an anonymous online forum. Unknown users (ROS nodes) may publish messages to a thread (topic) while other users can go to that thread and see (subscribe) that post. In this starter project, the Perception node subscribes to the /zed/left/image topic, which sends image frames from the ZED stereo camera approximately 60 times per second. The Perception node also publishes to the /tag topic, which the Navigation node will subscribe to.
Custom Messages
Section titled “Custom Messages”Different nodes often want to transmit different types and amounts of data. For example, a camera feed would be a continuous stream of massive RGB pixel matrices while a button sensor might publish a simple boolean state (pressed or not pressed). ROS enables this customization through Messages by allowing you to define your own message templates. Below, you can see the custom message type we have defined for you in msg/StarterProjectTag.msg. The name of the .msg file defines what the message type is called inside your C++ code.
int32 tag_idfloat32 x_tag_center_pixelfloat32 y_tag_center_pixelfloat32 closeness_metricPerception Starter Project
Section titled “Perception Starter Project”Inputs
Section titled “Inputs”- Image data in the form of
Imagemessages published to the/zed/left/imagetopic
Outputs
Section titled “Outputs”- One message published to
/tagtopic containing data about the closest detected ArUco tag:- The tag’s ID
- The x-coordinate of the center of the tag in the image
- The y-coordinate of the center of the tag in the image
- A closeness metric representing how far away the tag is
For this project, you will implement the functions in perception.cpp to identify the values of the above four variables, use them to construct a StarterProjectTag, and publish the message to the /tag topic for Navigation to read (“subscribe”) from.
From the terminal, make sure you are in the correct repository by running auton_starter and then build_starter to build the message file.
Code Overview
Section titled “Code Overview”To complete the Perception starter project, you will implement 7 functions of the Perception class:
- the Perception() constructor
- imageCallback()
- findTagsInImage()
- getClosenessMetricFromTagCorners()
- getCenterFromTagCorners()
- selectTag()
- publishTag()
Each of these functions have corresponding headers in perception.hpp that might be helpful. You shouldn’t have to create any other functions.
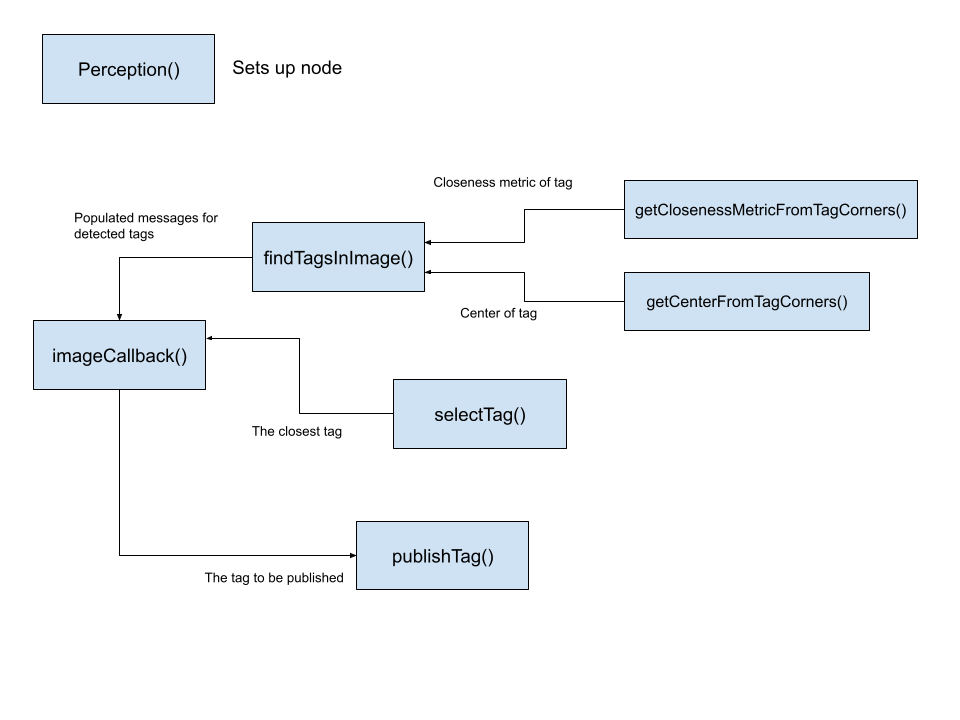
It’s a good idea to figure out what each function should do and how they interact with each other before you start writing code, so let’s go over what each function does at a very high level. The Perception() constructor creates the actual ROS node and sets up any persistent state it might need. imageCallback() is the only function that gets called every time a new image frame is published to the /zed/left/image topic (hint: it must cause all of the other functions to be called). findTagsInImage() makes the OpenCV call to detect the ArUco tags. getClosenessMetricFromTagCorners() should calculate a closeness metric for the detected tag. getCenterFromTagCorners() identifies the x and y coordinates of the center of the detected tag. selectTag() picks the closest tag, and publishTag() publishes it.
Based on the names of the functions, the parameters/return variables for each function, and various comments, identify:
- The inputs and outputs of each function
- The order each function will be called in
- Which functions call each other
Talk with the people around you and the autonomy leads if you have any questions! One possible working example is shown below. The direction of the arrows indicates the movement of data, not which function is calling which.
The Perception() constructor
Section titled “The Perception() constructor”Let’s take a look at the constructor Perception::Perception in perception.cpp. This constructor sets up the ROS node and is only run once. Once the constructor exits, any temporary information like local variables will be thrown away. Thus, we want any important work the constructor does to be assigned to class variables so that subsequent calls to class methods can benefit.
Setting the /zed/left/image Subscriber
Section titled “Setting the /zed/left/image Subscriber”Before we can figure out any high-level information like where the center of the detected tag is, we first need to get the actual camera frame. As detailed in the Inputs section, each frame from the camera is published to the topic /zed/left/image. The first thing the constructor does is read the camera frames using a subscriber. Take a look at the following code block:
mImageSubscriber = create_subscription<sensor_msgs::msg::Image>("/zed/left/image", 1, [this](sensor_msgs::msg::Image::ConstSharedPtr const& frame) { imageCallback(frame);});This code defines a subscriber that subscribes to the topic /zed/left/image. The [this] lambda syntax may look confusing, but all it’s doing is calling the imageCallback function, passing the camera frame as an argument. At a high level, when a new camera frame gets published to /zed/left/image, the subscriber calls imageCallback with the new camera frame. You can essentially think of this code ensuring that imageCallback gets called roughly 60 times per second every time a ZED frame is published.
Setting the /tag Publisher
Section titled “Setting the /tag Publisher”Now, uncomment the line starting with mTagPublisher. Once we’re done processing an image, we need to publish it to a topic so that other nodes, such as the Navigation node, can use our newly processed data. This is the job of a publisher, which publishes a message of a specific type to some topic. Therefore, we define a publisher that publishes StarterProjectTags to the topic /tag:
// TODO: uncomment me!// mTagPublisher = create_publisher<msg::StarterProjectTag>("/tag", 1);Setting the ArUco dictionary
Section titled “Setting the ArUco dictionary”Finally, we define the format of the tags we will be detecting by calling cv::aruco::getPredefinedDictionary(). The OpenCV library allows you to pick from various sets of valid markers. In this case we pick DICT_4x4_50, which means we guarantee that any ArUco tags we see will have 5x5 bit markers and an ID between 0-49. We’ll discuss this topic further when we actually perform the detections.
For now, by uncommenting the publisher, you’ve finished implementing the first function! Lucky for you, the rest of the functions will be a slightly more complex and require a bit of a creativity :)
imageCallback()
Section titled “imageCallback()”Let’s move on to the imageCallback() function. From here on out, the details will be relatively sparse, since there is no “correct” solution or structure, so be creative! Consider what work this function should do and what functions it should call. In the example above, it called findTagsInImage(), publishTag(), and selectTag().
Converting the Image
Section titled “Converting the Image”There are a few lines already in imageCallback() for you:
cv::Mat imageBGRA{static_cast<int>(imageMessage->height), static_cast<int>(imageMessage->width),              CV_8UC4, const_cast<uint8_t*>(imageMessage->data.data())};cv::Mat image;
cv::cvtColor(imageBGRA, image, cv::COLOR_BGRA2BGR);
These three lines convert from BGRA to BGR (blue-green-red) by removing the alpha (transparency) channel, and store the resulting BGR image in the image variable. This is to help you, since you do not need imageBGRA for the starter project and should only use the image variable.
findTagsInImage()
Section titled “findTagsInImage()”As the name suggests, this function’s goal is to extract all ArUco tags from the image parameter and place them into the tags output vector. To achieve this goal, consider what other functions you might want to call from this function. In the example diagram above, this function called getCenterFromTagCorners() and getClosenessMetricFromTagCorners().
Detecting ArUco Tags with OpenCV
Section titled “Detecting ArUco Tags with OpenCV”First, we want to detect any ArUco tags in the current camera frame. You will want to use the cv::aruco::detectMarkers() function for this. This example from OpenCV should give you an idea for what parameters you need to pass. Try to write it yourself, and then check with the answer below.
The correct call
cv::aruco::detectMarkers(image, mTagDictionary, mTagCorners, mTagIds);
getCenterFromTagCorners()
Section titled “getCenterFromTagCorners()”This function’s goal is to find the xy-coordinates of the center between the four corners for each tag. There’s a few different ways to implement this function, so we won’t provide a strategy or design to do it. Discuss with your partners/people around you and leads! There are a few edge cases, but this function does not need to account for them. For this project, simple can be better than complicated.
Coordinates in Camera Space
Section titled “Coordinates in Camera Space”The xy-coordinates are based off of (0,0) being the top left of the image. Both the corners populated by detectMarkers() and the coordinates expected by navigation in the output message follow this convention, so you don’t need to worry about converting anything.
Consider the following representation of a 23x15 image. The coordinate system starts at the top left corner with positive values of x extending right and positive values of y extending downward.

Hint: once cv::aruco::detectMarkers() is called, mTagCorners and mTagIds should contain the xy-coordinates of the corners and IDs (0-49) of the tags. Each four-tuple of corners is ordered as follows: top-left, top-right, bottom-right, bottom-left. mTagIds and mTagCorners are indexed the same; that is, the corners in mTagCorners[0] represent the corners of the tag with ID mTagIds[0].
getClosenessMetricFromTagCorners()
Section titled “getClosenessMetricFromTagCorners()”It’s important to have some kind of closeness metric, since it identifies how far away a tag is (and if we’re moving, whether or not we’re getting closer to it). Again, there are a few different ways to implement this function, so we won’t tell you how to do it. Be creative!
For a closeness metric, you only need a rough estimate. It will be used to drive towards the tag and stop within a distance. Consider how you as a human would estimate how far something is from you. How would you approximate how far the vehicles in the image below are from you? How do you know they are different distances away? Be creative!
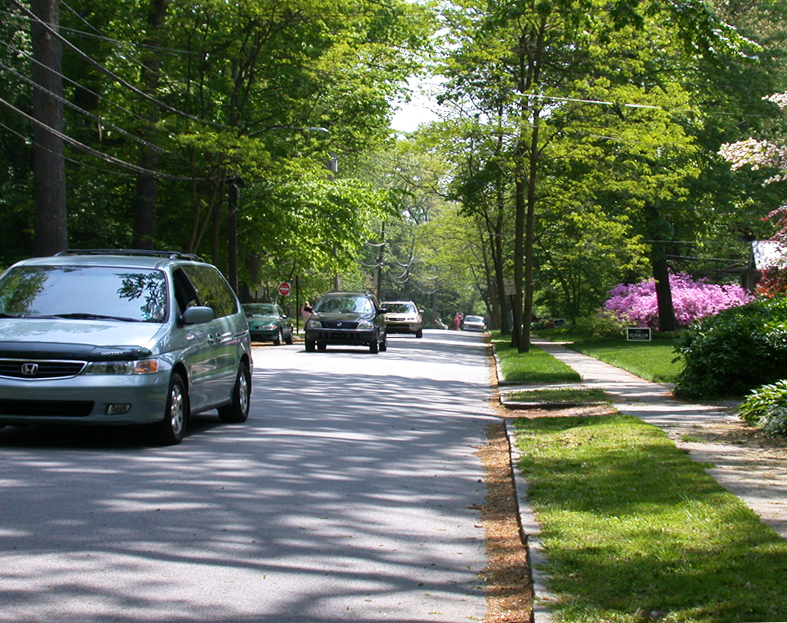
However you choose to implement the closeness metric, make sure to scale the number between 0 and 1 (where 0 is very close and 1 is far away), as the navigation starter project expects a range between these two numbers.
selectTag()
Section titled “selectTag()”We want to select the closest tag from the vector findTagsInImage() populates, since it makes sense to drive towards closer objects compared to farther ones. In other words, we want to pick the tag with the highest closeness metric.
If there are no valid ArUco tags in frame, you should publish a “dummy” tag with an ID of -1.
publishTag()
Section titled “publishTag()”Now that we have our desired tag, it is time to publish it to the proper topic. Implement Perception::publishTag. If you are unsure of the syntax, this example or a quick Google search will help you out. Check the answer once you think you’ve got it.
The correct call
mTagPublisher->publish(tag);
Putting It All Together
Section titled “Putting It All Together”To test, run ros2 launch mrover_autonomy_starter starter_project.launch.py to open the simulator. In another terminal window, run ros2 topic echo /tag to monitor the output of perception. Don’t forget to auton_starter to set up each terminal window. Make sure your node (the code you wrote) is not crashing in the log output! ros2 topic echo /tag should at least be continuously publishing invalid tags with ID of -1.
You can drive the rover around by pressing p to enable physics, and then move with i,j,l, and ,. In the RViz window, press “Add” in the bottom left, then click the “by topic” tab, scrolling down and selecting the “/zed”, “/left”, “/image”, “Image” option, and click “OK”. This should open a small window in the bottom left displaying what the ZED camera sees inside the simulator. If you navigate the rover such that you can see the ArUco tag in the camera feed, but ros2 topic echo /tag isn’t publishing a valid (not -1) tag, you might have some errors in your code.
Otherwise, congratulations! You have successfully completed the perception starter project!
Debugging with VS Code
Section titled “Debugging with VS Code”As a disclaimer, it can be difficult to use a debugger with MRover software, and various tools like ros2 topic echo and print statements are usually more helpful. However, it is possible to use VS Code to debug the starter project. First, comment out perception_node from the starter_project.launch.py file. Now, when the starter project is launched, it won’t launch the perception node. You will instead be separately launching it from VS Code.
Now run ros2 launch mrover_autonomy_starter starter_project.launch.py in a terminal to launch the simulator and other two nodes.
In VS Code, hit Ctrl-Shift-P and run Cmake: Debug. Select “Unspecified” if it asks for a kit. Select the starter_perception target to run (these settings are also on the bottom bar).
Make sure to set breakpoints in the source code files! They can provide useful information that print statements can’t.